Unified Physical AI Architecture
From AI BSP and Runtime to On-device Intelligence and Model Orchestration
We integrate hardware-specific BSPs, accelerator runtimes and robotic interfaces to bring AI models onto real devices. Consistent workflows for model porting, optimization and validation support deployment across diverse robotic platforms.
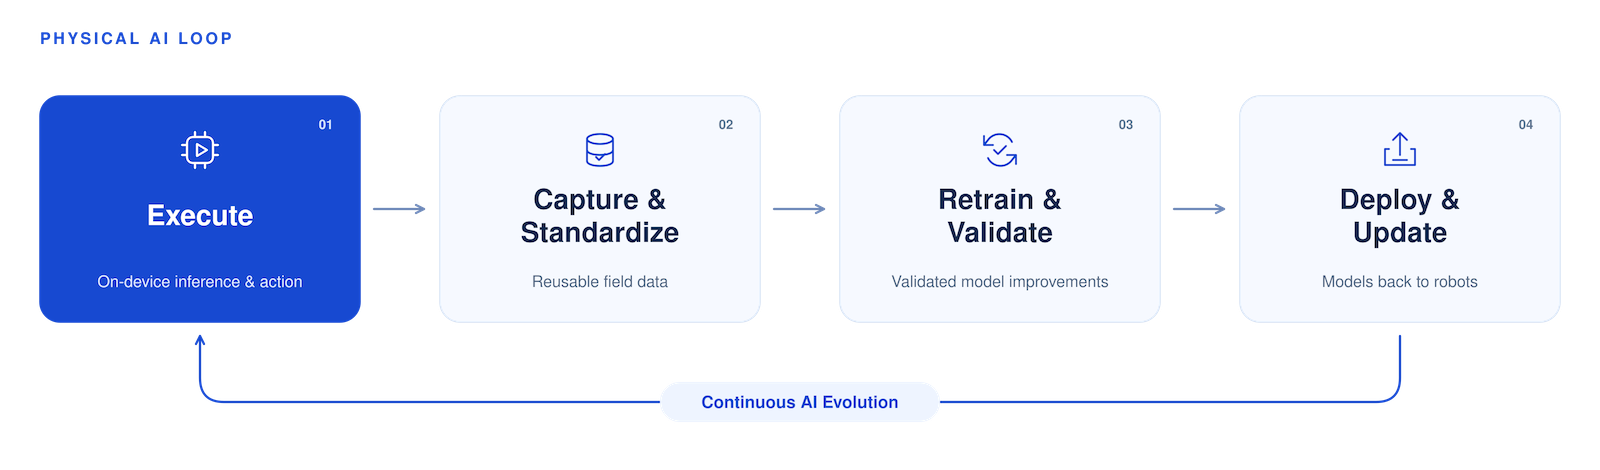
Connect standardized field data with model retraining, validation and redeployment—building Physical AI systems that improve through operational experience
AI BSP & Runtime · On-device Intelligence · Data & Model Orchestration
PLATFORM ARCHITECTURE
Three Platforms. One Physical AI Loop.
Connect edge execution, on-device intelligence and data and model operations in one architecture. Run AI across diverse robots and turn field experience into a continuous cycle of model improvement and redeployment.
01
AirPath®
Edge AI Compute, BSP & Runtime Platform
A Common Foundation for AI Execution
Integrate boot, kernel, drivers and accelerator runtimes into a deployment foundation for AI models and robotics software.
02
SynaAI®
Models, Inference & Decision Logic
From Real-World Context to Intelligent Action
Adapt models to field data and compose inference pipelines and decision logic for robotic perception, condition assessment and action.
03
FlyingLet® Synapse
Physical AI Orchestration & Data Platform
Connect Field Data to Continuous Improvement
Coordinate robot missions, field data and model operations across connected robotic systems.
AirPath®
Edge AI Compute, BSP & Runtime Platform
From AI Silicon
to Deployable Intelligence
BSPs, accelerated runtimes and robotic interfaces—engineered for deployment
AirPath® combines edge compute hardware with INTEGRIT’s system software and runtime technology. We engineer the stack from boot, kernel and drivers to sensor data paths and AI acceleration backends, then package it with SDKs and validation tools for robotic development and deployment
BSP & System Enablement
Board-specific Enablement. Maintainable System Software.
Port boot chains, kernels, device trees and I/O drivers, with integrated root filesystems, recovery and update configurations. Managed patches and board configurations provide an OS foundation for robotic products.
Boot & Kernel · Device Drivers · System Images
Sensor & Memory Integration
Optimize the Data Path from Sensors to Inference
Connect camera and media pipelines with shared-buffer paths, coordinating sensor timing, buffer lifetimes and cache coherency. Reduce unnecessary copies and stalls across capture, preprocessing and inference
V4L2 / GStreamer · DMA-BUF · Buffer Synchronization
AI Runtime & Backend Engineering
Map Model Graphs to Target Accelerators
Develop ONNX Runtime execution providers, ExecuTorch backends and compiler integrations for target hardware. Manage operator coverage, graph partitioning, fallback and compilation caches, with profiling of the resulting execution paths
Backend Adapters · Graph Partitioning · Runtime Profiling
Robotics SDK & Validation
Reproducible Workflows from Development to Device Validation
Package ROS 2 and robot SDK interfaces with reference pipelines and tools for model conversion, execution and profiling. Target-specific accuracy and performance checks, regression testing and version compatibility support repeatable deployment
ROS 2 Interfaces · Developer Toolchains · Regression Validation
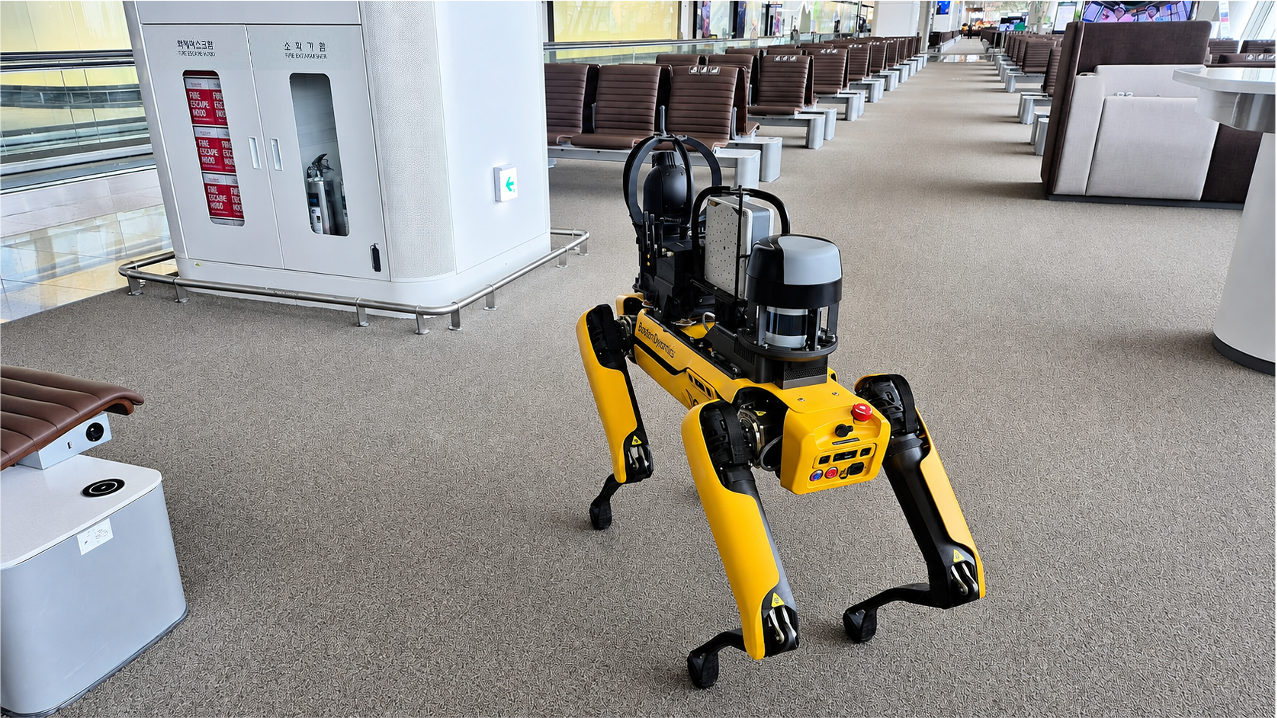
Extending Spot with On-Device AI for Low-Power Inspection
In an Incheon International Airport pilot, AirPath® connected to a Spot robot’s camera and mission data to run asset detection and condition assessment onboard. Robot SDK integration, authentication, time synchronization and data acquisition supported reporting to the airport’s monitoring system over a private 5G network.
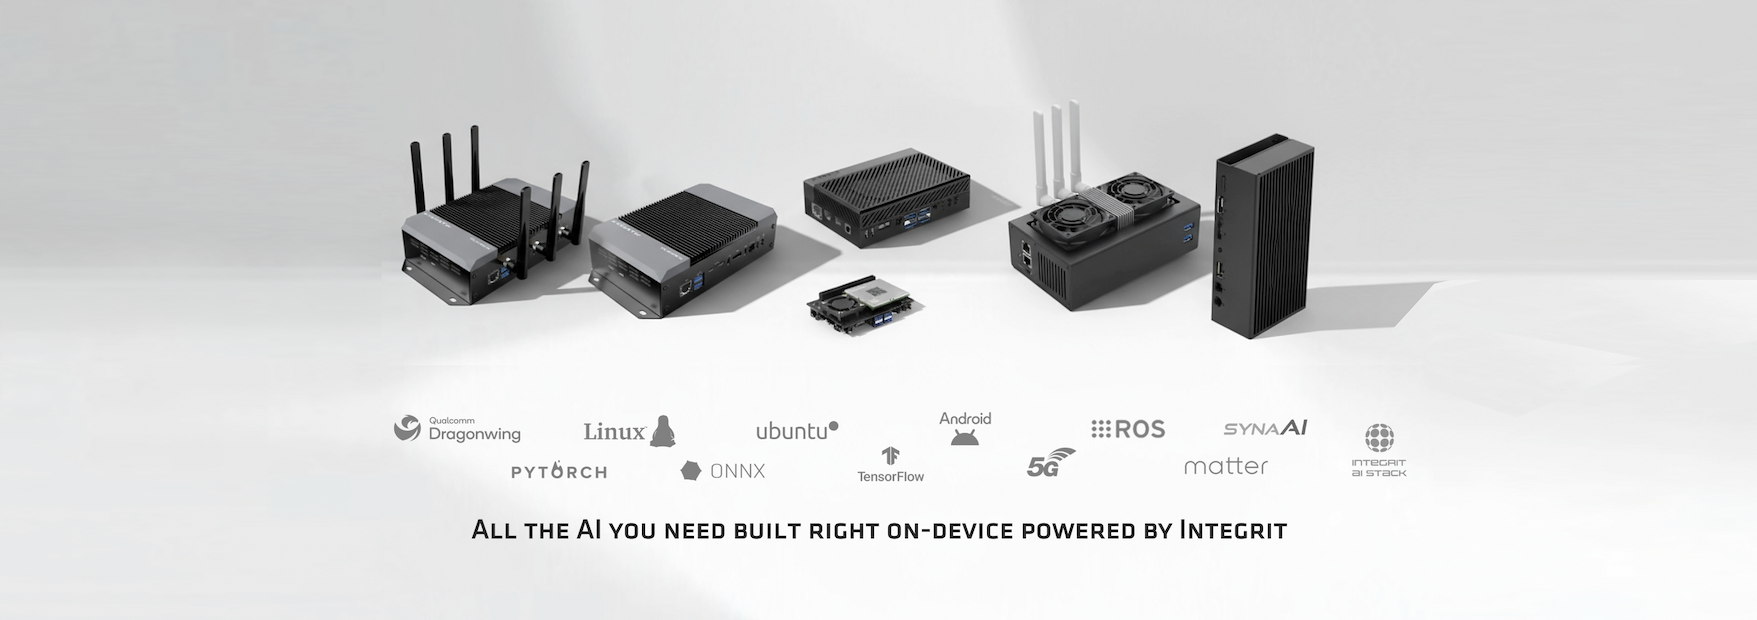
AirPath V4 Mcqueen
Integrated hardware, BSPs and runtimes for extending AI capabilities in service robots and quadrupeds.
Ultra-compact Physical AI for service robots & quadrupeds
Spot, Unitree 등 4족보행 로봇, 서비스 로봇에서 저전력 경량화된 온디바이스 기반의 sLM, VLA, RFM 을 지원하여, 로봇의 지각·이해·행동을 하나의 플랫폼에서 제공합니다.
Go to Youtube
AirPath v5 Stratus
A deployment foundation for video processing and AI inference in industrial robots and intelligent devices.
Physical AI for humanoids & mission-critical robotics
휴머노이드 로봇, 4족보행 로봇, 산업용 로봇의 온 디바이스 LLM, 인지, 추론, VLA 기반 자율주행 시스템을 빠르게 구축합니다.
Go to Toutube
AI Compute · BSP & System Software · Optimized AI Runtime
SYNA AI®
On-device AI Models & Inference Platform
Models Adapted to the Field. Execution Validated on the Robot
Integrate model adaptation, inference pipelines and decision logic on device.
Built on INTEGRIT’s AI models and inference framework, SynaAI® brings LLMs, VLMs, VLAs and task-specific vision models into robotic applications.
We adapt and optimize models with field data, compose preprocessing, inference and decision pipelines, and validate execution on target devices. Model outputs connect to robot missions, action interfaces and operational systems.
Model Adaptation · Composable Inference · Validated Execution
Domain Data & Model Adaptation
Adapt Models to Real Operating Conditions
Build training data around site-specific capture conditions and task requirements. Address scarce abnormal examples with controlled synthetic data and curation, then evaluate performance across capture domains.
Task Data · Controlled Augmentation · Domain Evaluation
Composable Inference Pipelines
Compose Models into Task-specific Workflows
Connect preprocessing and context construction with model execution. Combine detection, classification, anomaly detection, language reasoning and action planning as required, using conditional branches and postprocessing to produce task-relevant outputs.
Multimodal Inputs · Pipeline Composition · Conditional Execution
On-device Optimization & Validation
Optimize for the Device. Validate the Result
Apply model compression, quantization and target-specific execution configurations to address compute and memory constraints. Compare reference and on-device outputs on the same evaluation data, assessing accuracy, latency and model size before deployment
Quantization · Target Profiling · Output Validation
Decision Logic & Robot Interfaces
Turn Model Outputs into Operational Results
Apply input-quality checks, confidence thresholds and task rules to connect model outputs with status, mission and action interfaces. Route uncertain results for review and attach asset, location and mission context for robotic and operational systems
Quality Gates · Robot Adapters · Structured Results
Foundational Onboard Intelligence
with Integrated RFM & Physical AI
AirPath V4 McQueen with On-Device RFM Platform
AirPath® AI bSP 와 SynaAI 플랫폼의 통합으로 서비스 로봇, 4족 보행 플랫폼, 휴머노이드, 스마트 홈 로봇 등광범위한 로봇 시스템에서 Physical AI 브레인으로 활용될 수 있는 개방형 환경을 제공합니다
SynaA®I 이 제공하는 4족보행 로봇과 휴머노이드 로봇의 초경량 LLM 과 VLA 자율주행 플랫폼
AirPath V4 McQueen 플랫폼은 초저지연·저전력·고성능의 AI 추론을 온디바이스에서 직접 실행하며, LLM, 비전-언어-동작 통합 모델(VLA), 로봇 파운데이션 모델(RFM)을 지원합니다
Go to AirPath® V4 McQueen
SynaAI®, 비전·음성·상황 정보를 통합하는 멀티모달 인지(VLA)와 행동 생성 엔진을 통합한 RFM (Robot Foundation Model)
SynaAII®는 비전·음성·환경 정보를 통합하는 멀티모달 인지(VLA) 와 행동 계획 엔진(RFM)을 통해, 로봇이 실시간 상황을 해석하고, 행동을 결정하도록 구성된 Physical AI 아키텍처입니다. 엣지단에서 자율 추론을 수행하여 빠르고 안정적으로 동작하는 로봇 시스템을 구축 합니다.
SynaAI는 월드 모델 기반 상황 추론 행동 생성 엔진으로 전 과정을 온디바이스에서 처리합니다.
SynaAI는 AI 홈 에이전트, 컨싱지로봇과 4족보행 로봇 등 다양한 로봇에 이식되어, 다중 AI 모델을 효과적으로 수행하고 있습니다
Go to SynaAI®
AirPath V4 @ On-Device RFM Platform
Qualcomm Dragonwing QCS8550 기반의 초소형, 초경량 AI 엣지 플랫폼으로 AI 서비스 로봇에서 4족보행로봇, 홈로봇읜 온디바이스 AI 확장을 제공합니다
Ultra-compact Physical AI for service robots & quadrupeds
Spot, Unitree 등 4족보행 로봇, 서비스 로봇에서 저전력 경량화된 온디바이스 기반의 sLM, VLA, RFM 을 지원하여, 로봇의 지각·이해·행동을 하나의 플랫폼에서 제공합니다.
Go to Youtube
Physical AI for humanoids & mission-critical robotics
Qualcomm의 최신 Dragonwing IQ-9075 기반의 고성능 플래그쉽 AI 엣지 플랫폼으로 산업용에서 휴머노이드까지 광범위한 AI 확장을 제공합니다
AirPath® V5, Redefining Humanoid Intelligence with Physical AI
휴머노이드 로봇, 4족보행 로봇, 산업용 로봇의 온 디바이스 LLM, 인지, 추론, VLA 기반 자율주행 시스템을 빠르게 구축합니다.
Go to Toutube