Unified Physical AI Architecture
From AI BSP and Runtime to On-device Intelligence and Model Orchestration
We integrate hardware-specific BSPs, accelerator runtimes and robotic interfaces to bring AI models onto real devices. Consistent workflows for model porting, optimization and validation support deployment across diverse robotic platforms.
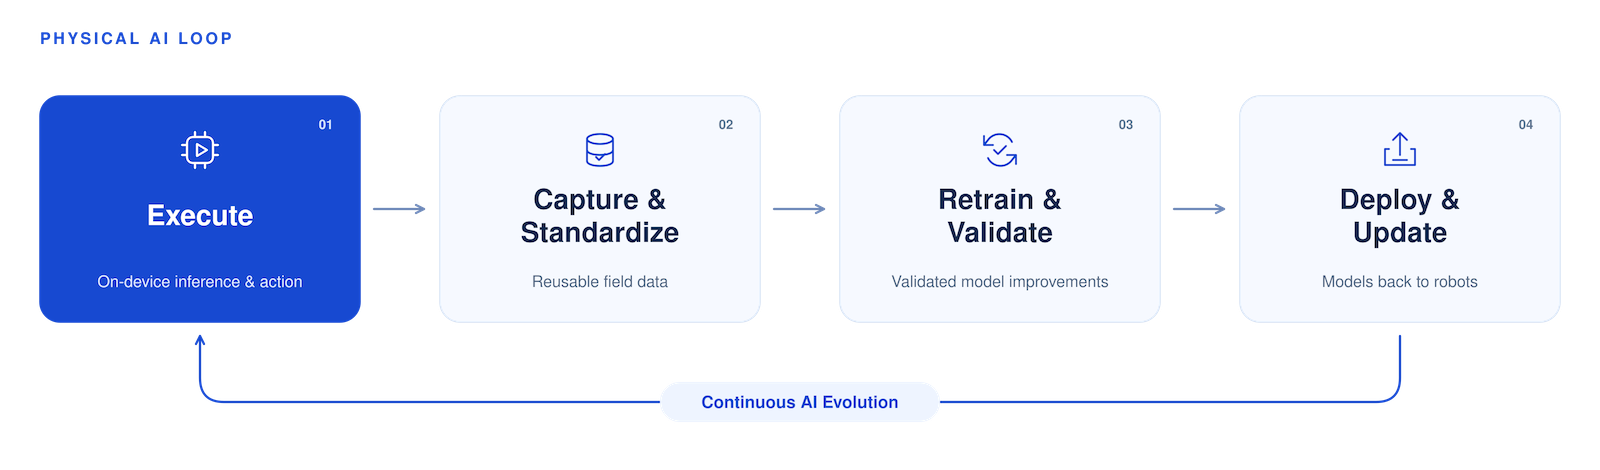
Connect standardized field data with model retraining, validation and redeployment—building Physical AI systems that improve through operational experience
AI BSP & Runtime · On-device Intelligence · Data & Model Orchestration
PLATFORM ARCHITECTURE
Three Platforms. One Physical AI Loop.
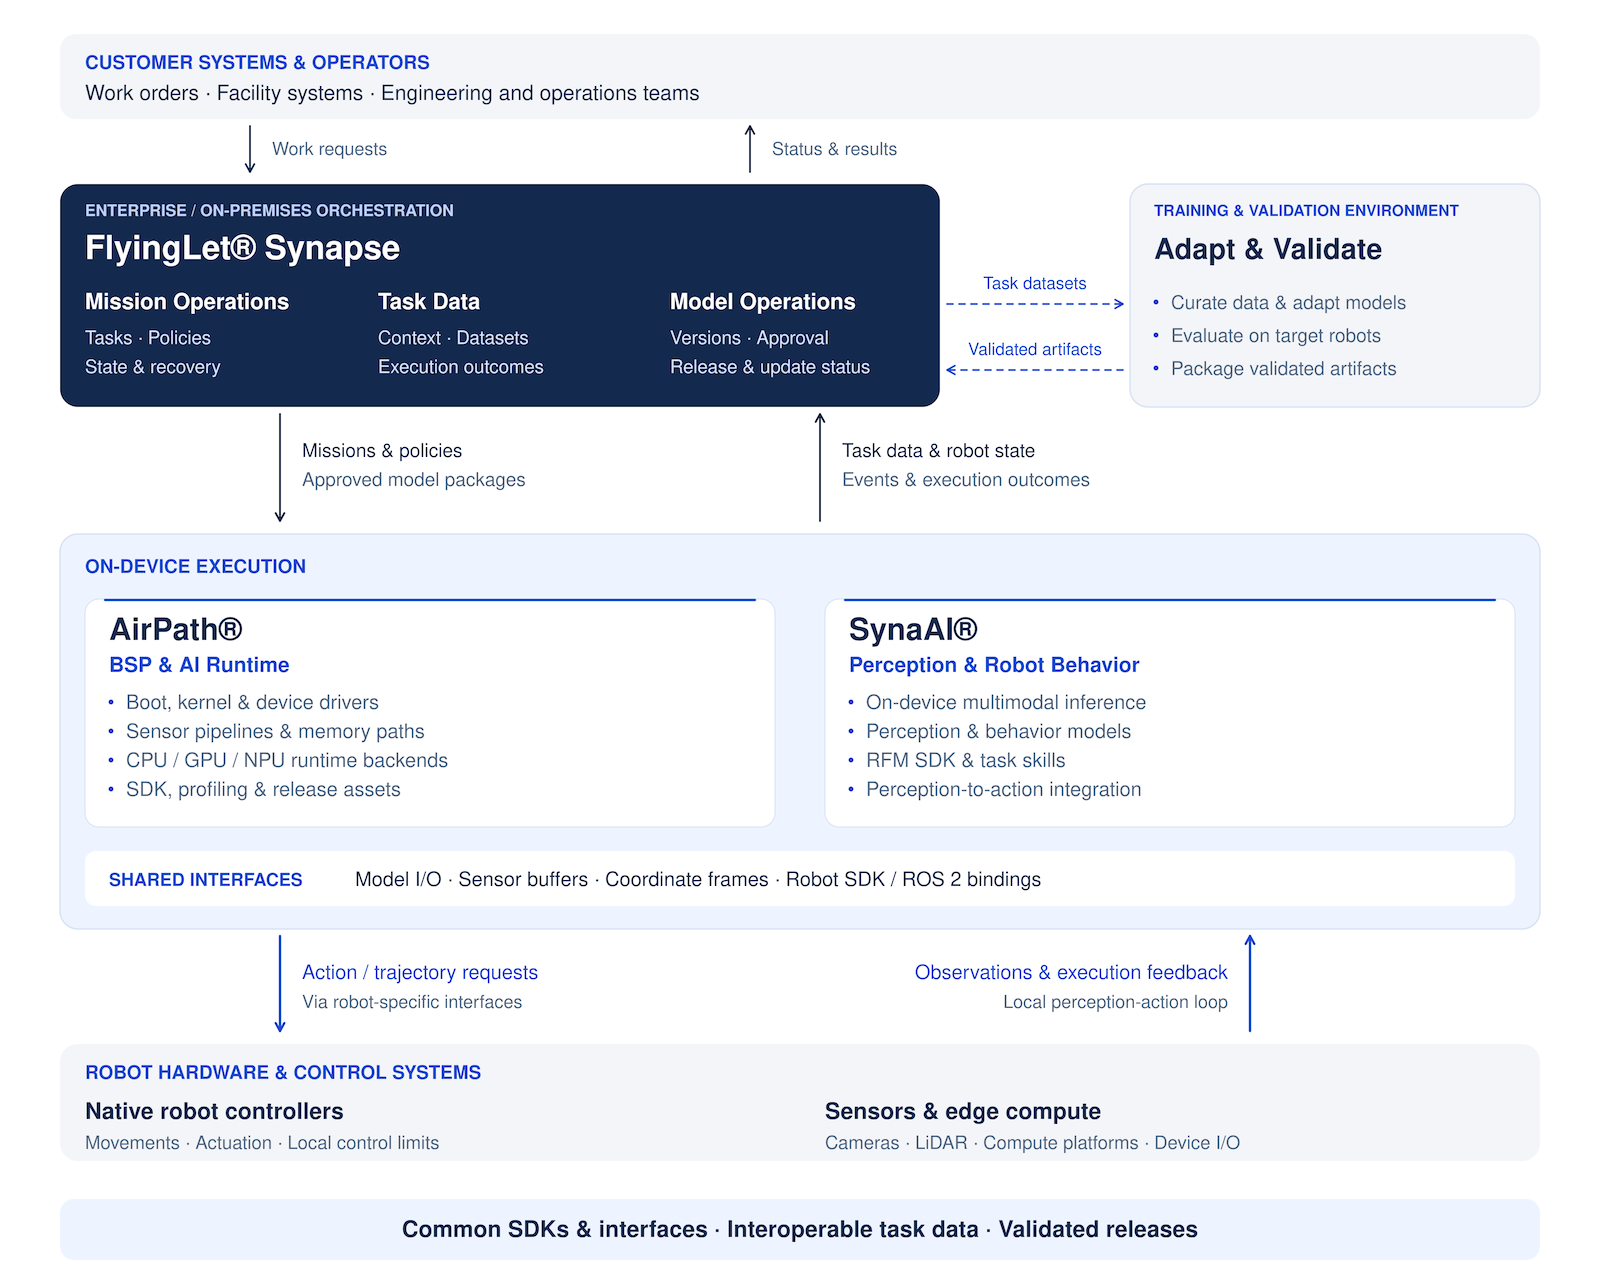
Connect edge execution, on-device intelligence and data and model operations in one architecture. Run AI across diverse robots and turn field experience into a continuous cycle of model improvement and redeployment.
01
AirPath®
Edge AI Compute, BSP & Runtime Platform
A Common Foundation for AI Execution
Integrate boot, kernel, drivers and accelerator runtimes into a deployment foundation for AI models and robotics software.
02
SynaAI®
Models, Inference & Decision Logic
From Real-World Context to Intelligent Action
Adapt models to field data and compose inference pipelines and decision logic for robotic perception, condition assessment and action.
03
FlyingLet® Synapse
Physical AI Orchestration & Data Platform
Connect Field Data to Continuous Improvement
Coordinate robot missions, field data and model operations across connected robotic systems.
AirPath®
Edge AI Compute, BSP & Runtime Platform
From AI Silicon
to Deployable Intelligence
BSPs, accelerated runtimes and robotic interfaces—engineered for deployment
AirPath® combines edge compute hardware with INTEGRIT’s system software and runtime technology. We engineer the stack from boot, kernel and drivers to sensor data paths and AI acceleration backends, then package it with SDKs and validation tools for robotic development and deployment

AIRPATH® ARCHITECTURE
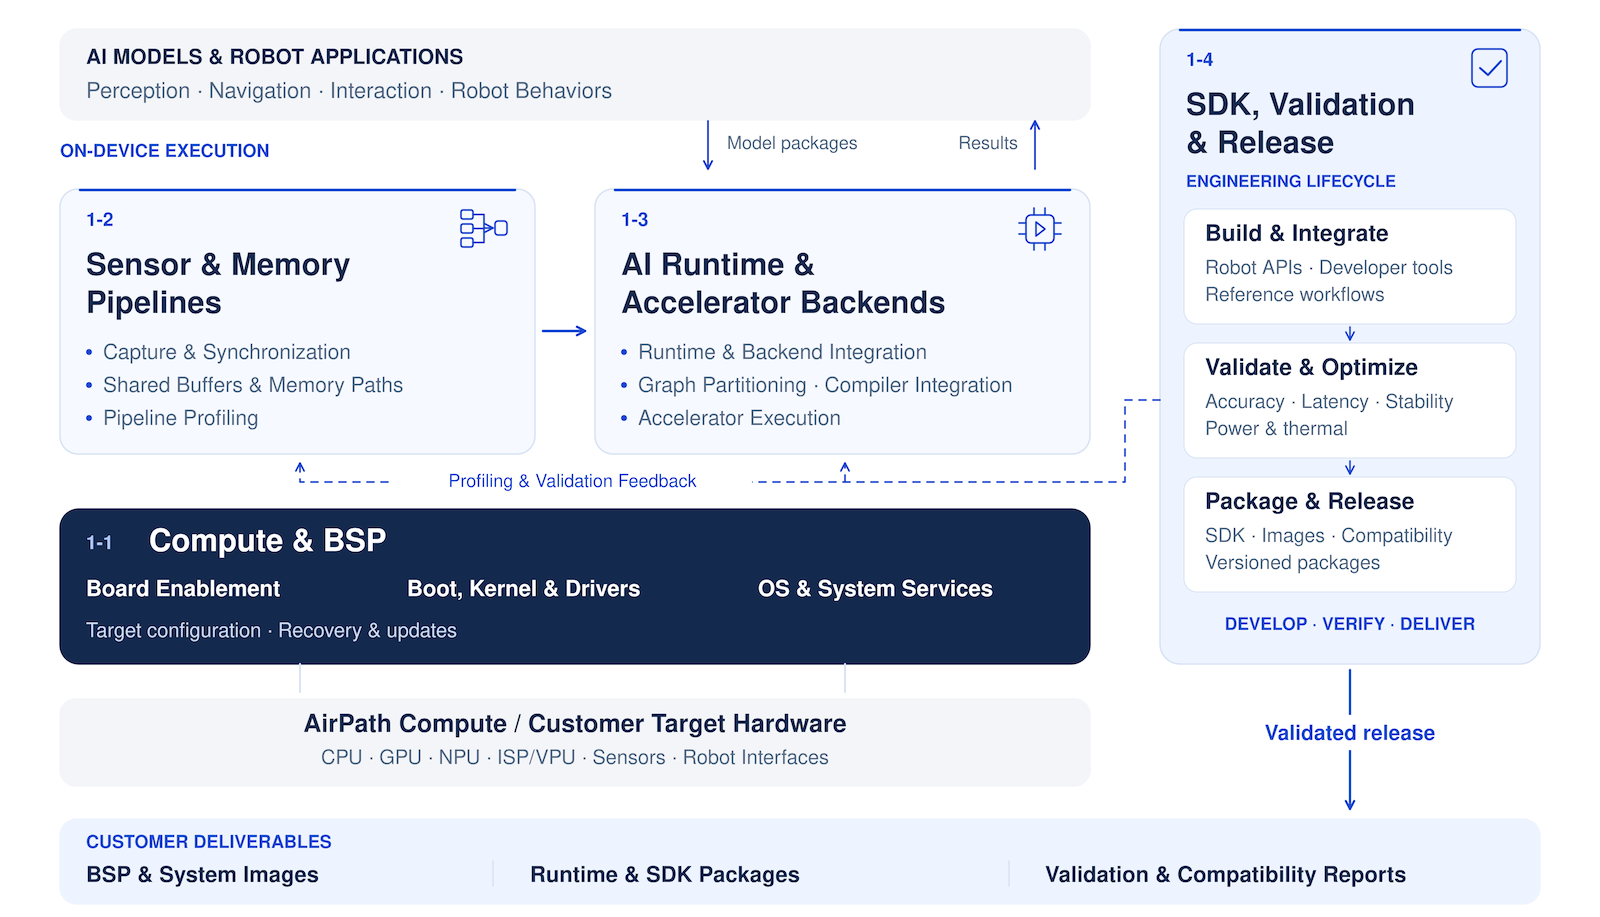
Connect BSP, sensor pipelines and AI runtime through a common SDK, validation and release workflow.
AirPath® connects board bring-up, OS and drivers with sensor and memory pipelines and accelerator runtimes. Reusable platform assets are adapted to your hardware and robot interfaces, supporting model and application porting.
A common SDK provides a repeatable workflow for development and target validation. Accuracy, performance, stability and version compatibility are verified, with validated configurations delivered as system images, runtime components and SDK packages to support product integration and updates.
BSP & System Enablement
Board-specific Enablement. Maintainable System Software.
Port boot chains, kernels, device trees and I/O drivers, with integrated root filesystems, recovery and update configurations. Managed patches and board configurations provide an OS foundation for robotic products.
Boot & Kernel · Device Drivers · System Images
Sensor & Memory Integration
Optimize the Data Path from Sensors to Inference
Connect camera and media pipelines with shared-buffer paths, coordinating sensor timing, buffer lifetimes and cache coherency. Reduce unnecessary copies and stalls across capture, preprocessing and inference
V4L2 / GStreamer · DMA-BUF · Buffer Synchronization
AI Runtime & Backend Engineering
Map Model Graphs to Target Accelerators
Develop ONNX Runtime execution providers, ExecuTorch backends and compiler integrations for target hardware. Manage operator coverage, graph partitioning, fallback and compilation caches, with profiling of the resulting execution paths
Backend Adapters · Graph Partitioning · Runtime Profiling
Robotics SDK & Validation
Reproducible Workflows from Development to Device Validation
Package ROS 2 and robot SDK interfaces with reference pipelines and tools for model conversion, execution and profiling. Target-specific accuracy and performance checks, regression testing and version compatibility support repeatable deployment
ROS 2 Interfaces · Developer Toolchains · Regression Validation
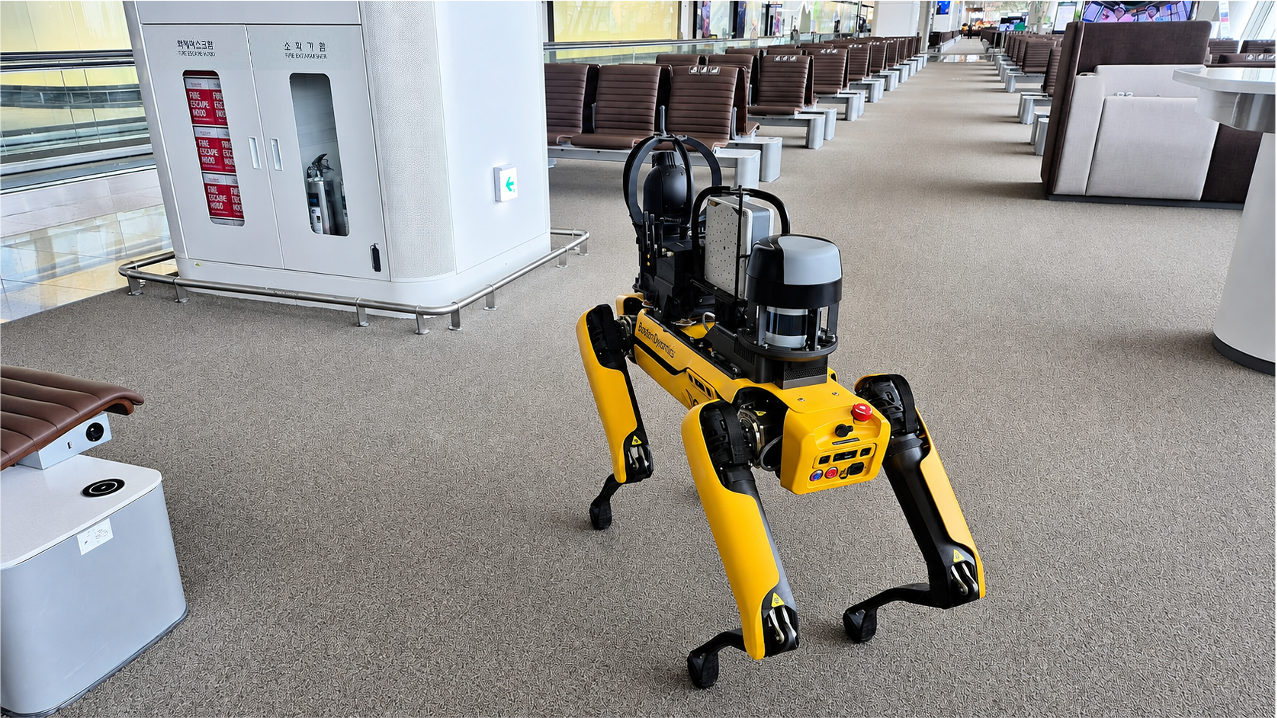
Extending Spot with On-Device AI for Low-Power Inspection
In an Incheon International Airport pilot, AirPath® connected to a Spot robot’s camera and mission data to run asset detection and condition assessment onboard. Robot SDK integration, authentication, time synchronization and data acquisition supported reporting to the airport’s monitoring system over a private 5G network.
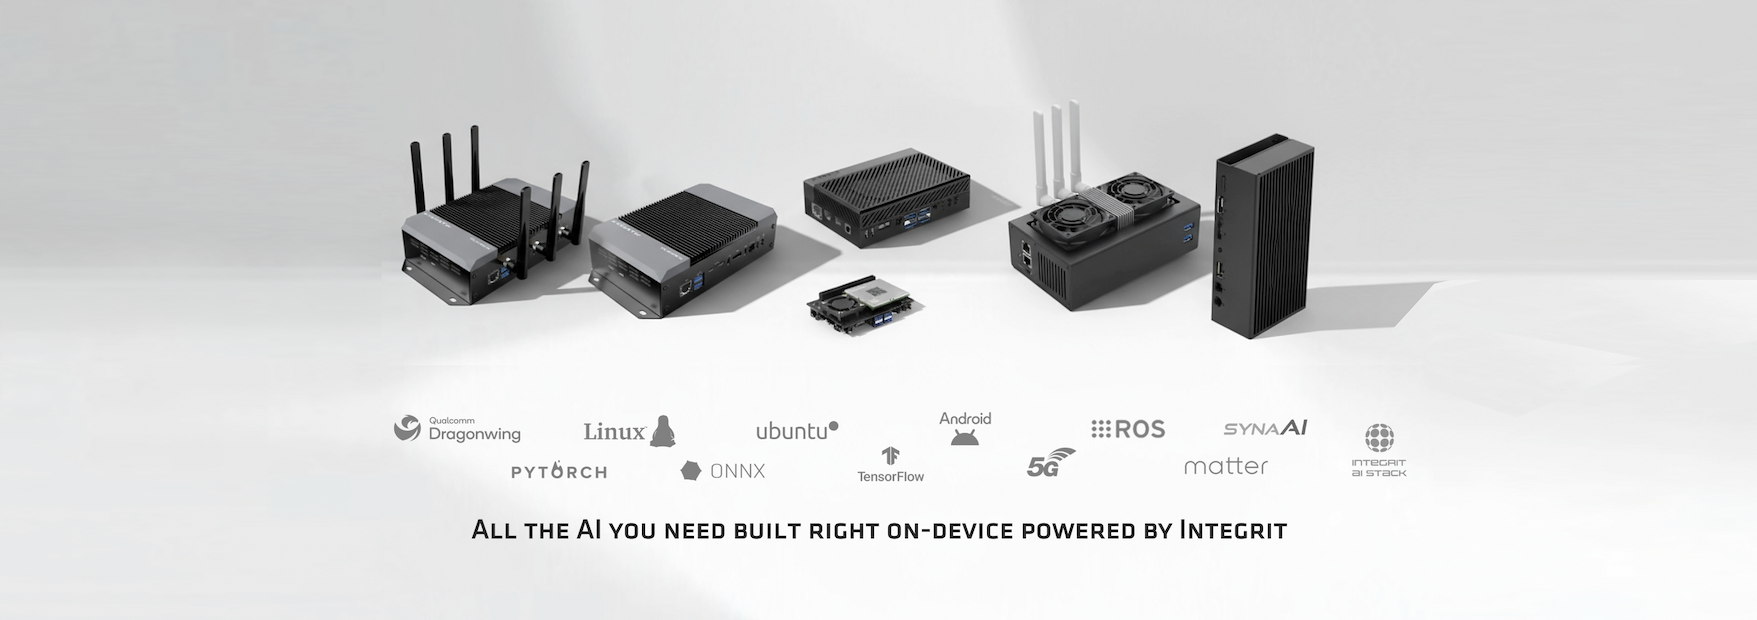
AirPath V4 Mcqueen
Integrated hardware, BSPs and runtimes for extending AI capabilities in service robots and quadrupeds.
Ultra-compact Physical AI for service robots & quadrupeds
Spot, Unitree 등 4족보행 로봇, 서비스 로봇에서 저전력 경량화된 온디바이스 기반의 sLM, VLA, RFM 을 지원하여, 로봇의 지각·이해·행동을 하나의 플랫폼에서 제공합니다.
Go to Youtube
AirPath v5 Stratus
A deployment foundation for video processing and AI inference in industrial robots and intelligent devices.
Physical AI for humanoids & mission-critical robotics
휴머노이드 로봇, 4족보행 로봇, 산업용 로봇의 온 디바이스 LLM, 인지, 추론, VLA 기반 자율주행 시스템을 빠르게 구축합니다.
Go to Toutube
AI Compute · BSP & System Software · Optimized AI Runtime
SynaAI®
On-device AI & Robot Behavior Platform
On-device Intelligence.
Robot Behaviors. Predictive AI
Integrate model adaptation, inference pipelines and decision logic on device.
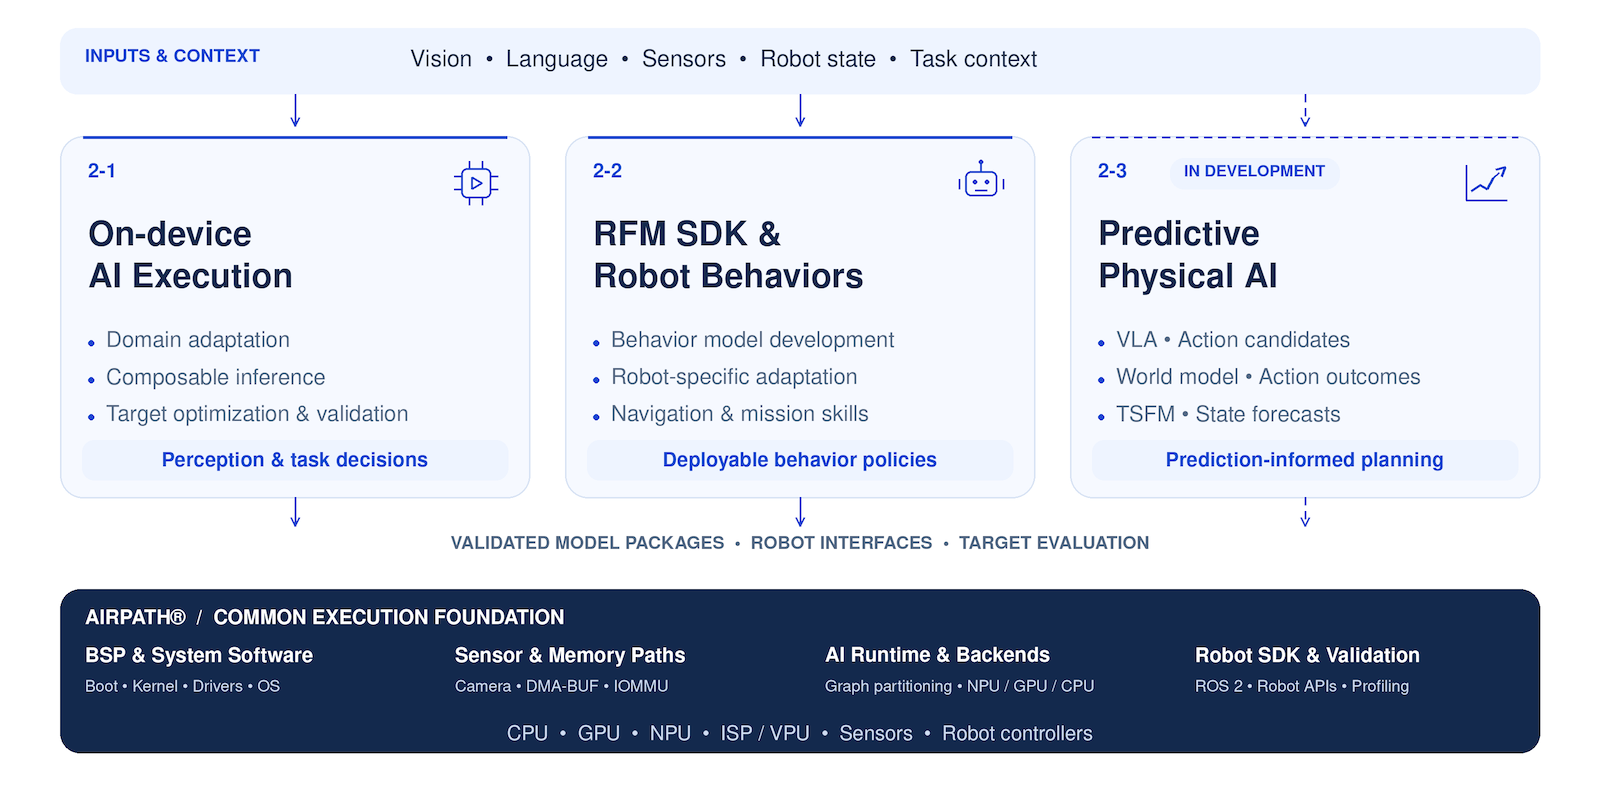
SynaAI® connects field-adapted AI models with on-device execution and robot behavior development through INTEGRIT’s proprietary RFM SDK. Validated models run on the AirPath® BSP and AI runtime, with robot-specific interfaces enabling new capabilities and missions.
Our research extends this foundation toward predictive Physical AI, integrating VLA, world models and time-series foundation models to bring anticipated outcomes and future states into robotic decision-making.
On-device Intelligence · Robot Behaviors · Predictive AI
Domain Data & Model Adaptation
Adapt Models to Real Operating Conditions
Build training data around site-specific capture conditions and task requirements. Address scarce abnormal examples with controlled synthetic data and curation, then evaluate performance across capture domains.
Task Data · Controlled Augmentation · Domain Evaluation
Composable Inference Pipelines
Compose Models into Task-specific Workflows
Connect preprocessing and context construction with model execution. Combine detection, classification, anomaly detection, language reasoning and action planning as required, using conditional branches and postprocessing to produce task-relevant outputs.
Multimodal Inputs · Pipeline Composition · Conditional Execution
On-device Optimization & Validation
Optimize for the Device. Validate the Result
Apply model compression, quantization and target-specific execution configurations to address compute and memory constraints. Compare reference and on-device outputs on the same evaluation data, assessing accuracy, latency and model size before deployment
Quantization · Target Profiling · Output Validation
Decision Logic & Robot Interfaces
Turn Model Outputs into Operational Results
Apply input-quality checks, confidence thresholds and task rules to connect model outputs with status, mission and action interfaces. Route uncertain results for review and attach asset, location and mission context for robotic and operational systems
Quality Gates · Robot Adapters · Structured Results
FlyingLet® Synapse
Mission, Data & Model Orchestration
Orchestrate Robot Missions. Advance Physical AI.
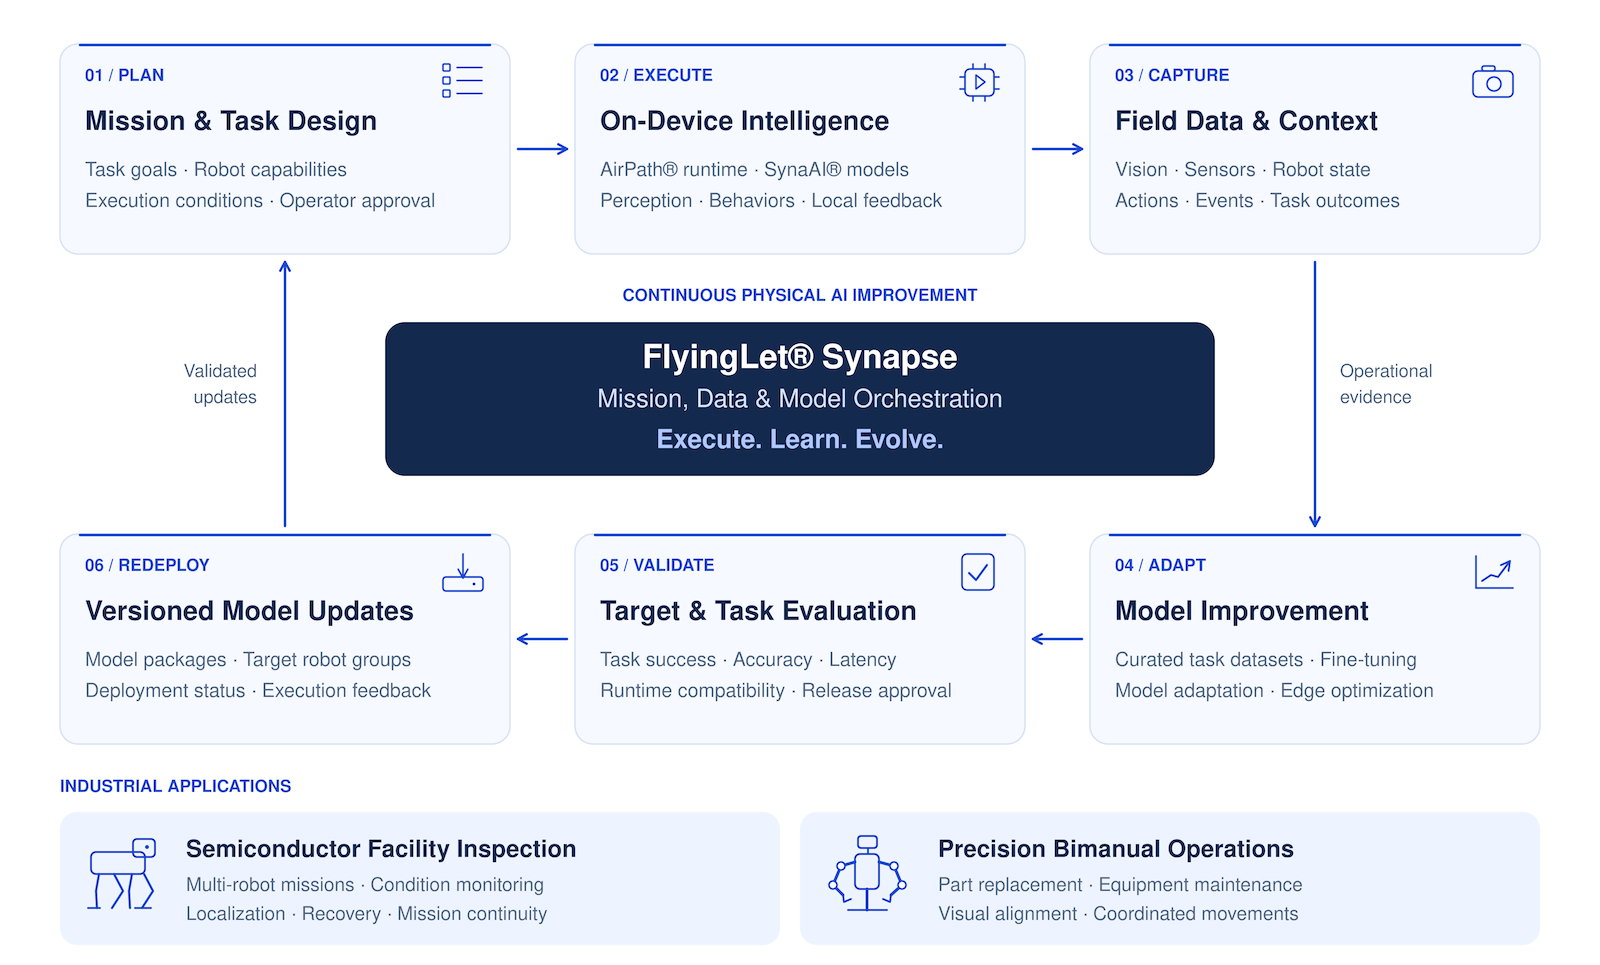
FlyingLet® Synapse connects robot missions, on-device intelligence, field data and model operations within a unified enterprise platform. From multi-robot inspection in semiconductor facilities to precision bimanual operations, it coordinates field execution, operational recovery and continuous AI improvement.
Mission Orchestration · Connected Edge Execution · Data & Model OperationsI
Turn Field Experience into Validated AI Updates
FlyingLet® Synapse connects task goals, robot capabilities and execution conditions to shape each mission. It captures visual observations, sensor readings, robot states and action outcomes with their task context—building structured data for operational analysis and model improvement.
The platform connects this data to evaluation, retraining and optimization workflows, then coordinates validated model updates for target robots. Missions, datasets, model versions and deployment results remain linked, making field experience traceable through each improvement cycle.
With AirPath® providing the BSP and AI runtime foundation and SynaAI® supplying perception and behavior models, FlyingLet connects execution, learning and redeployment into a continuous Physical AI loop.